راهنمایی جامع و گامبهگام برای درک اصول رباتیک و ساخت برنامههای رباتیکی خودتان، در عرض چند روز — نه ماهها.
ویژگیهای کلیدی:
- ایجاد پایهای محکم در ROS 2 و تقویت اعتمادبهنفس برای پروژههای آتی در حوزه رباتیک
- بهرهگیری از بهترین روشها برای توسعه اپلیکیشنهای مقیاسپذیر با استفاده از ROS 2، در زبانهای Python و C++
- دنبال کردن یک روند آموزشی گامبهگام برای طراحی و شبیهسازی یک ربات سفارشی با استفاده از ROS 2
توضیحات کتاب:
“ROS 2 از صفر” نوشتهی یکی از بنیانگذاران شرکت رباتیک با سالها تجربه در آموزش و مهندسی، مهارتهای لازم برای توسعه سیستمهای پیشرفته رباتیکی را به شکلی کارآمد در اختیار شما قرار میدهد.
این کتاب کمک میکند تا ابتدا به درک روشنی از اینکه چرا باید از سیستمعامل ربات (ROS) استفاده کنیم برسید، و توضیح میدهد که ROS چه هست و چه نیست. تمرکز کتاب بر یادگیری عملی است — بدون حاشیهپردازی غیرضروری، بدون تئوری انتزاعی، و بدون پرش ناگهانی به مباحث پیچیده.
شما خواهید آموخت چگونه ROS 2 را نصب کنید، محیط کاری را پیکربندی نمایید، و مفاهیم را از طریق تمرینهای عملی تجربه کنید. در ادامه یک برنامه واقعی ROS 2 برای یک ربات سفارشی خواهید ساخت.
فصلها به تدریج مفاهیم کلیدی مانند نودها، ارتباط از طریق تاپیکها، تعامل کلاینت-سرور با سرویسها، رفتارهای پیچیده با استفاده از اکشنها، پیکربندی زمان اجرا با پارامترها، و سازماندهی نودها با فایلهای لانچ را پوشش میدهند.
هر مفهوم با استفاده از مثالهای واقعی و قیاسهای قابلفهم، به زبانهای Python و C++ به شکلی شفاف توضیح داده میشود.
در ادامه پروژهای واقعی شامل TF، مدلسازی با URDF، نمایش در RViz، و شبیهسازی در Gazebo را خواهید ساخت.
آنچه در این کتاب خواهید آموخت:
- درک اینکه ROS 2 چیست، چه زمانی و چگونه باید از آن استفاده کرد
- نوشتن برنامههای ROS 2 با استفاده از نودها، تاپیکها، سرویسها، اکشنها و واسطهای سفارشی
- مقیاسپذیر کردن برنامه با استفاده از پارامترها و فایلهای لانچ
- شناخت کامل عملکرد TF برای هر ربات مبتنی بر ROS
- ساخت مدل ربات با URDF و نمایش TFها در RViz
- تطبیق URDF برای فراخوانی و کنترل ربات در شبیهساز Gazebo
مخاطب این کتاب:
این کتاب برای مهندسان، پژوهشگران، معلمان، دانشجویان و علاقهمندان به رباتیک طراحی شده که میخواهند از صفر، یادگیری ROS 2 را آغاز کنند و بهصورت کارآمد، برنامههای واقعی توسعه دهند.
اگر شروع کار با ROS 2 برایتان دشوار بوده یا منابع آموزشی دیگر برایتان گیجکننده بهنظر میرسند، این کتاب دقیقاً برای شما نوشته شده است.
برای استفاده از این کتاب، فقط آشنایی اولیه با خط فرمان لینوکس و برنامهنویسی Python کافی است (دانش C++ فقط برای دنبال کردن مثالهای C++ لازم است).
A comprehensive, step-by-step guide to understanding the basics of robotics and creating your own robotics applications within days, not months
Key Features
- Build a strong foundation in ROS 2 and instill confidence for future robotics projects
- Leverage best practices to create scalable ROS 2 applications with Python and C++
- Follow a step-by-step process to create and simulate a custom robot using ROS 2
Book Description
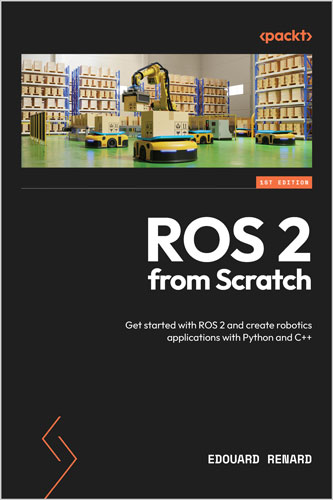
ROS 2 from Scratch, written by the cofounder of a robotics company with years of experience in teaching and engineering, will equip you with the skills necessary to develop cutting-edge robotic systems efficiently.
This book will help you understand why you should use Robot Operating System (ROS), clarifying what ROS is and isn’t. It focuses on applied learning—no unnecessary filler, no abstract theory, and no abrupt leaps into complex topics. You’ll discover how to install ROS 2, set up your environment, and explore concepts through hands-on experiments, as well as create a ROS 2 application for a custom robot. The chapters expand upon core concepts such as nodes, communication via topics, client-server interactions with services, complex behaviors using actions, runtime configurations with parameters, and seamless node orchestration via launch files. Each concept is clearly explained with the help of real-life analogies and practical examples, using Python and C++. The book will also guide you through creating a real-world project that incorporates TFs, URDF, RViz, and Gazebo.
By the end of this book, you’ll be able to create new software for any robot in no time and easily join existing projects for new job roles, research endeavors, and beyond.
What you will learn
- Understand what ROS 2 is, when to use it, and how to use it
- Write ROS 2 programs using nodes, topics, services, actions, and custom interfaces
- Scale your application with parameters and launch files
- Get a complete overview of how TFs work for any ROS-powered robot
- Create a robot model (with URDF) and visualize TFs on RViz
- Adapt the URDF to spawn and control your robot in the Gazebo simulator
Who this book is for
This book is for engineers, researchers, teachers, students, and hobbyists eager to learn ROS 2 from scratch and build real-world robotics applications efficiently. If you’re struggling to get started with ROS 2 or find existing tutorials overwhelming, then this book is for you. This book teaches you all the basics you need to create your own ROS 2 apps, without prior ROS knowledge. Basic Linux command line and Python programming skills (C++ optional for following the C++ code examples) are necessary.
Table of Contents
- Introduction to ROS 2 – What Is ROS 2?
- Installing and Setting Up ROS 2
- Uncovering ROS 2 Core Concepts
- Writing and Building a ROS 2 Node
- Topics – Sending and Receiving Messages between Nodes
- Services – Client/Server Interaction between Nodes
- Actions – When Services Are Not Enough
- Parameters – Making Nodes More Dynamic
- Launch Files – Starting All Your Nodes at Once
- Discovering TFs with RViz
- Creating a URDF for a Robot
- Publishing TFs and Packaging the URDF
- Simulating a Robot in Gazebo
- Going Further – What to Do Next
About the Author
Edouard Renard is a software engineer, entrepreneur, and robotics teacher. In 2016, he cofounded a robotics start-up as CTO, developing and selling an educational 6-axis robotic arm based on Robot Operating System (ROS). Since 2019, he has been teaching robotics programming online. He is the best-selling instructor on Udemy for ROS 2 and has published many additional free tutorials on his website and YouTube channel (Robotics Back-End). He also leads offline workshops for professionals in Singapore and the US. His teaching philosophy is as follows: step by step, practical, and to the point.


نقد و بررسیها
هنوز بررسیای ثبت نشده است.