در ویرایش چهارم این کتاب، با خلق برنامههای نرمافزاری رباتیک که جدیدترین فناوریها مانند هوش مصنوعی مولد (Generative AI) و یادگیری تقویتی را به کار میگیرند، به تسلط کامل بر ROS 2 دست یابید و ربات دلخواه خود را بسازید.
ویژگیهای کلیدی:
- آشنایی گامبهگام با مفاهیم پایه و ویژگیهای اصلی ROS 2
- طراحی، شبیهسازی و نمونهسازی برنامههای رباتیک با استفاده از ROS 2، زبانهای C++، ROS و شبیهساز Gazebo
- تجربهی عملی با فناوریهای نوین مانند GenAI و یادگیری تقویتی، یکپارچهشده با ROS 2 Jazzy
توضیحات کتاب:
افزایش تقاضا برای نرمافزارهای پیشرفتهی رباتیک، مهارت در فریمورکهایی نظیر ROS 2 را برای مهندسان و علاقهمندان ضروری ساخته است.
Lentin Joseph، یکی از بنیانگذاران RUNTIME Robotics، و Jonathan Cacace، دکترای رباتیک، در این ویرایش جامع و چهارم که مطابق با آخرین نسخهی بلندمدت پشتیبانیشده ROS 2 Jazzy در سال ۲۰۲۴ بهروزرسانی شده، شما را با مفاهیم بنیادی و کاربردهای عملی آشنا میکنند.
پس از معرفی جامع ROS 2 و اجزای اصلی آن، فصلهای کتاب شما را آماده برنامهنویسی و استفاده مؤثر از قابلیتهای کلیدی این فریمورک میکند. سپس، تمرکز کتاب به شبیهسازی و مدلسازی سهبعدی رباتها با استفاده از Gazebo Sim و کنترلرهای ROS 2 معطوف میشود. در ادامه، ویژگیهای پیشرفتهای مانند Nav2 (برای ناوبری) و MoveIt 2 (برای عملیات حرکتی) بررسی میشوند، که برای توسعه سیستمهای پیشرفته ضروری هستند.
در فصلهای بعدی، وارد دنیای رباتهای پرنده با ROS 2 میشوید و یاد میگیرید چگونه با استفاده از Micro-ROS رباتهایی واقعی بسازید. فصلهای پایانی به مباحث پیشرفتهتری مانند جریانهای کاری CI/CD، تعامل ROS 2 با عاملهای مبتنی بر مدلهای زبانی بزرگ (LLM) برای برنامهریزی هوشمند، و همچنین استفاده از یادگیری تقویتی عمیق برای ایجاد خودمختاری میپردازند.
آنچه در این کتاب خواهید آموخت:
- بررسی عمیق معماری ROS 2، سیستم DDS و رابطهای ارتباطی
- شبیهسازی انواع رباتها با استفاده از Gazebo و ROS 2
- تسلط بر Nav2 و MoveIt 2 در ROS 2
- کار با ros2_control و سیستمهای درک محیط (Perception)
- ساخت و برنامهنویسی یک ربات متحرک واقعی با برد Raspberry Pi و ROS 2
- ساخت عاملهای هوش مصنوعی مبتنی بر LLM در ROS 2
- پیادهسازی یادگیری تقویتی در ROS 2، NVIDIA Isaac Lab و Isaac Sim
مخاطب این کتاب:
اگر از علاقهمندان، پژوهشگران یا متخصصان نرمافزار هستید که به دنبال ارتقای مهارتهای خود در ROS 2 میباشید، این کتاب برای شما مناسب است. توسعهدهندگان ROS که میخواهند ویژگیهای پیشرفتهی ROS 2 را بیاموزند نیز از این کتاب بهرهمند خواهند شد. برای شروع، آشنایی مقدماتی با ROS، سیستمعامل GNU/Linux و برنامهنویسی C++ و Python ضروری است.
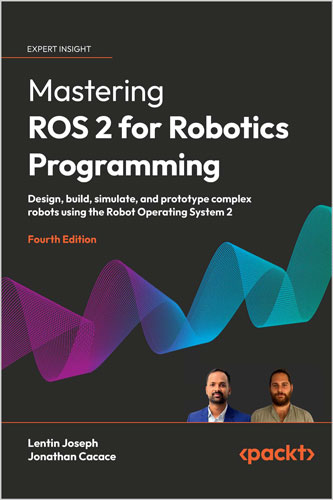
In this fourth edition, master ROS 2 by creating robotics software applications that integrate the latest technologies, like Generative AI and reinforcement learning, to build your custom robot.
Key Features
- Get a solid understanding of ROS 2 core concepts and features from scratch
- Design, simulate, and prototype robotic applications using ROS 2, C++, Python, and Gazebo
- Gain hands-on experience with the latest technologies like GenAI and reinforcement learning, integrated with ROS 2 Jazzy
Book Description
The rising demand for advanced robotics software has made proficiency in frameworks like ROS 2 essential for engineers and enthusiasts alike.
Lentin Joseph, co-founder of RUNTIME Robotics, and Jonathan Cacace, PhD in robotics, help you grasp the foundational concepts and practical applications in this comprehensive fourth edition updated to cover the latest LTS release from 2024—ROS 2 Jazzy. Starting with a solid introduction to ROS 2, including core components and tools, the chapters get you ready to start programming and using its key features confidently. Building on this, the book focuses on 3D robot modeling and simulation with the new Gazebo Sim, supported by ROS 2 controllers. You’ll explore high-level features such as Nav2 for navigation and MoveIt 2 for manipulation, which are crucial for developing advanced systems. You’ll also dive into aerial robotics with ROS 2 and learn how to build real-world robots using Micro-ROS. The concluding chapters cover advanced topics like CI/CD workflows, interfacing ROS 2 with large language model (LLM) agents for intelligent planning, and applying deep reinforcement learning for autonomy.
By the end of this book, you’ll have a strong foundation in ROS 2, along with the skills needed to build sophisticated, real-world robotic applications.
What you will learn
- Explore ROS 2 architecture, DDS, and communication interfaces in depth
- Simulate various robots using Gazebo and ROS 2
- Master Nav2 and MoveIt 2 in ROS 2
- Explore ros2_control and Perception
- Build and program a real mobile robot from scratch using Raspberry Pi board and ROS 2
- Build LLM-based AI agents in ROS 2
- Implement reinforcement learning applications in ROS 2, NVIDIA Isaac Lab, and Isaac Sim
Who this book is for
If you are a robotics enthusiast, researcher, or software professional looking to advance your skills in ROS 2, this book is for you. ROS developers who wish to explore the advanced features of ROS 2 will also find this book helpful. Basic knowledge of ROS, GNU/Linux, and C++, as well as Python programming concepts is necessary to get started with this book.
Table of Contents
- Introduction to ROS 2
- Getting Started with ROS 2 Programming
- Implementing ROS 2 Concepts
- Working with Robot 3D Modeling in ROS 2
- Simulating Robots in a Realistic Environment
- Controlling Robots Using the ros2_control Package
- Implementing ROS 2 Applications Using BehaviorTree dot CPP
- ROS 2 Navigation Stack: Nav2
- Robot Manipulation Using MoveIt 2
- Working with ROS 2 and Perception Stack
- Aerial Robotics and ROS 2
- Designing and Programming a DIY Mobile Robot from Scratch
- Testing, Continuous Integration, and Continuous Deployment with ROS 2
- Interfacing Large Language Models with ROS 2
- ROS 2 and Deep Reinforcement Learning
- Implementing ROS 2 Visualization and Simulation Plugins
About the Author
Lentin Joseph is an accomplished Indian roboticist, author, entrepreneur, and educator with over a decade of expertise in robotics software development, machine vision, and artificial intelligence. He is the founder and CTO of RUNTIME Robotics Pvt Ltd, an Indian company focused on R&D in robotics software development and artificial intelligence. He also runs robocademy, an online platform for robotics education. With strong proficiency in ROS, OpenCV, and PCL, Lentin has authored 10 widely acclaimed books on robotics, including Learning Robotics Using Python and Mastering ROS for Robotics Programming. He holds a bachelor’s degree in Electronics and Communication Engineering from FISAT and a master’s in Robotics and Automation from Amrita University. During his studies, he developed a gesture- and speech-interactive social robot that gained media attention. Lentin has also conducted research at Carnegie Mellon University’s Robotics Institute, delivered a TEDx talk, and actively contributes to robotics education through workshops, blogs, and training programs.
Jonathan Cacace was born in Naples, Italy, on 13 December 1987. He earned a Bachelor’s and Masters of Science in Computer Science from the University of Naples Federico II. He then joined the university’s PhD program, earning the title of Philosophiae Doctor in Automation and Computer Engineering in 2016. During his research career, he had the opportunity to participate in and lead various applied research projects focused on robotics, funded by the European Union. This allowed him to explore several areas of robotics, ranging from robot manipulation to navigation.After completing his PhD, he continued his scientific research and work in applied robotics, contributing to more than 50 scientific publications in leading robotics conferences and scientific journals. He also worked as a private consultant for several startups across Europe. From 2019 to 2023. He worked as an assistant professor at the University of Naples, where he taught two courses: Laboratory of Robotics and Mobile Robotics. During this time, he mentored many undergraduate students in the field of Robotics and Computer Engineering. He was also invited to speak at an international robotics workshop held at one of Europe’s most prestigious research centers and universities.Currently, Jonathan works as a senior researcher in the field of Cognitive Robotics and Human-Robot Interaction at Eurecat – Centre Tecnològic de Catalunya in Barcelona.


نقد و بررسیها
هنوز بررسیای ثبت نشده است.